Linear Algebra: UNIT II: Linear Transformations and Diagonalization
Matrix Representation of a Linear Transformation: Example Solved Problems Using Theorems
Important Theorems for Engineering Maths or Mathematics - Matrix Representation of a Linear Transformation: Example Solved Problems Using Theorems
MATRIX
REPRESENTATION OF A LINEAR TRANSFORMATION
EXAMPLE PROBLEMS USING
THEOREMS
Example 13
Let T: R2 → R3
and U: R2 → R3 be the linear transformations respectively
defined by T(a1, a2)
= (a1 +3a2, 0, 2a1−4a2) and U(a1, a2) = (a1−a2, 2α1,
3a1+2a2)
Then prove that [T+U]γβ
= [ T ]γβ + [U]γβ
Solution:
Let
T: R2 → R3 and U: R2 → R3.
T(a1, a2)=(a1+3a2, 0, 2a1−4a2) and
U
(a1, a2) = (a1−a2, 2a1, 3a1+2a2)
Let
β and γ be the standard ordered bases for R2 and R3
respectively.
Let
β = {(1, 0), (0, 1)} and
γ = { (1, 0, 0), (0, 1, 0), (0, 0, 1)}
T
(v1) = T (1, 0) = 1 (1, 0, 0) + 0 (0, 1, 0) + 2 (0, 0, 1)
[ T(a1, a2)
= (a1+3a2, 0, 2a1 − 4a2)] (ie), a1 = 1 and a2 =0
=
(1, 0, 0) + (0, 0, 0) + (0, 0, 2)
=
(1,0, 2)
T(v2)
= T(0, 1) = 3(1, 0, 0) + 0(0, 1, 0) −4(0, 0, 1)
=
(3, 0, 0) + (0, 0, 0)+(0, 0, −4)
=
(3, 0, −4)
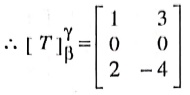
...(1)
Let
β ={(1, 0), (0, 1))
γ = { (1, 0, 0), (0, 1, 0), (0, 0, 1) }
U
(v1) = U (1, 0) = 1 (1, 0, 0) + 2 (0, 1, 0) + 3 (0, 0, 1)
[
U (a1, a2)
= (a1 − a2, 2a1, 3a1
+2a2)]
= (1,
0, 0) + (0, 2, 0) + (0, 0, 3)
= (1, 2, 3)
(ie) a1
= 1 and a2 = 0
U
(v2)=U (0, 1) = −1 (1, 0, 0) + 0 (0, 1, 0) + 2 (0, 0, 1)
=(−1,
0, 0)+(0, 0, 0)+(0, 0, 2)
=
(−1, 0, 2)
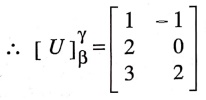
...(2)
Now
let us compute T+U, then
(T+U)
(a1, a2) = (a1 +3a2, 0, 2a1−4a2)+(a1−a2, 2a1, 3a1+2a2)
=
(2a1+2a2, 2a1, 5a1−2a2)
(T+U)
(v1) = (T+U) (1, 0) = 2 (1, 0, 0)+2 (0, 1, 0) + 5 (0, 0, 1)
=
(2, 0, 0)+(0, 2, 0)+(0, 0, 5)
=
(2,2,5)
(T+U)
(v2) = (T+U) (0, 1) = 2 (1, 0, 0)+0 (1, 0, 0)−2 (0, 0, 1)
=
(2, 0, 0) + (0, 0, 0) + (0, 0, − 2)
=
(2, 0, −2)
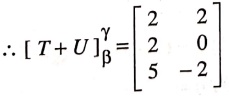
...(3)
Now
let us compute
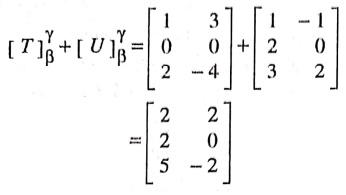
From
equations (3) & (4) we have proved that
[T+U]γβ
= [ T ]γβ + [U]γβ
Example 14
Let T: R2→R3,
be the linear transformation defined by T (a1, a2)
= (a1+3a2, 0, 2α1−4a2).
Let β be the standard ordered basis of R2 and R3. Then
prove that [aT]γβ =a[T]γβ for all
scalars a.
Solution:
Let
T: R2→R3
T
(a1, a2) = (a1 +3a2, 0, 2a1 − 4a2)
Let
β
= {(1, 0), (0, 1)} and
γ=
{(1, 0, 0), (0, 1, 0), (0, 0, 1)}
aT
(v1) = aT (1, 0) = (a, 0, 2a)
(Refer the previous example)
aT
(v2) = aT (0, 1) = (3a, 0, −4a)
(Refer the previous example)
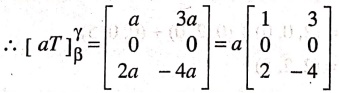
...(1)
We
know that from the previous example
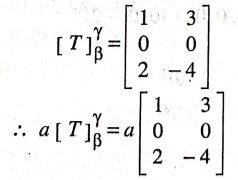
...(2)
From
equations (1) & (2) it is proved as
[aT]γβ
=a[T]γβ for all scalars a.
Example 15
Let V be the vector
space of complex number over R. Let T: V→ V defined by T (Z)= ,
where is the complex conjugate. Prove that T is linear and then
compute [T]β where β={1,i}
Solution:
Let
us consider the complex number Z= a + ib
Here
a and b are all real numbers.
Given
that T: V→V defined by T(Z)= = (a−ib)
.
T (a+ib) = a – ib ⇒ T (a, b) = (a, − b)
To
prove T is linear let us consider
T[x
(a + ib) + y (c+id)] = T [(xa+yc) + i (xb+yd)]
=
(xa + yc) ‒ i(xb + yd)
=
(xa ‒ ixb) + (yc−iyd)
=
x(a−ib) + y (c−id)
=
xT(a+ib) + yT(c+id)
T
is linear.
It
is given that the basis is β = { 1, i }
⇒ {1+0i, 0+ li}
=
{(1, 0), (0, 1)}
Let
v1 = (1, 0) and v2 = (0, 1)
T(v1)=T(1,
0) = (1, 0) = 1
T(v2)=T(0,
1) = (0,−1) = −i (T(z)= )
T(v1)=T(1,
0) = T (1, 0) = 1 (1, 0)+0 (0, 1)
=
(1, 0)+(0, 0)
=
(1, 0)
T(v2)
= T (0, − 1) = 0 (1, 0) ‒ 1 (0, 1)
=
(0, 0) + (0, − 1)
=
(0,−1)
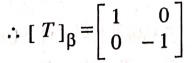
Example 16
Let V be n−dimensional vector space with an
ordered basis β, which is defined by T : V→Fn by T (x)= [x]β.
Prove that it is linear.
Solution:
It
is given that V is an n−dimensional vector space over F and sional vector B = {
v1, v2 ... vn } is its basis.
Every
vector in V can be written as a linear combination of β = { v1, v2,
v3 ... vn }.
Also
T: V→Fn by T(x) = [x]β.
Here
[x]β is the coefficient of linear combination of
β
= { v1, v2... vn}
We
know that T(x+y) = T(x)+T (y)
and
also we know that [cx]β = c[x]β
Hence
T is linear.
Linear Algebra: UNIT II: Linear Transformations and Diagonalization : Tag: maths, mathematics : - Matrix Representation of a Linear Transformation: Example Solved Problems Using Theorems
Linear Algebra: UNIT II: Linear Transformations and Diagonalization
Under Subject

Linear Algebra
MA25C02 2nd Semester | 2025 Regulation
Related Subjects

English Essentials II
EN25C02 2nd Semester | 2025 Regulation | 2nd Semester 2025 Regulation

Tamils and Technology தமிழர்களும் தொழில்நுட்பமும்
UC25H02 2nd Semester | 2025 Regulation | 2nd Semester 2025 Regulation
Linear Algebra
MA25C02 2nd Semester | 2025 Regulation
Transforms and its Applications
MA25C03 2nd Semester EEE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Physics (CE) II
PH25C02 2nd Semester Civil, Agri Depts | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Physics (CSIE) II
PH25C03 2nd Semester AIDS, CSE, IT, CSE(CY) Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Applied Physics (EE) II
PH25C04 2nd Semester EEE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Physics (ME) II
PH25C05 2nd Semester Mechanical Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Applied Chemistry (CE) II
CY25C02 2nd Semester Civil Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Chemistry (ME) II
CY25C03 2nd Semester Mechanical Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Electron Devices
EC25C01 2nd Semester ECE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Digital Principles and Computer Organization
CS25C06 2nd Semester AIDS, CSE, IT, CSE(CY) Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Basic Electrical and Electronics Engineering
EE25C01 2nd Semester | 2025 Regulation | 2nd Semester 2025 Regulation

Basic Civil and Mechanical Engineering
GE25C01 2nd Semester EEE Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Data Structures using CPlusPlus
CS25C05 2nd Semester ECE Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Engineering Drawing
ME25C01 EEE, Mech, Agri, EEE Depts | 2025 Regulation | 2nd Semester 2025 Regulation
Data Structures and Algorithms
CS25C04 2nd Semester EEE Dept | 2025 Regulation

Circuits and Network Analysis
EC25C02 2nd Semester ECE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Engineering Mechanics
ME25C02 2nd Semester Mech, Civil, Agri Depts | 2025 Regulation | 2nd Semester 2025 Regulation
Object Oriented Programming (OOPs)
CS25C07 2nd Semester CSE, CSE(CY) Depts | 2025 Regulation | 2nd Semester 2025 Regulation