Linear Algebra: UNIT II: Linear Transformations and Diagonalization
System of Differential Equations
Important Example Solved Problems - Engineering Maths or Mathematics - System of Differential Equations
SYSTEM OF DIFFERENTIAL
EQUATIONS
Example 18
Consider the system of
differential equations
x'1=3x1+x2+x3
x'2 = 2x1 + 4x2
+ 2x3
x'3 = −x1−x2+x3
where, for each i, xi=xi(t)
is a differential real−valued function of the real variable t. Find the general
solution:
Solution
Let
x: R → R3 be the function defined by
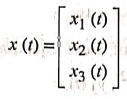
The
derivative of x denoted by x', is defined by 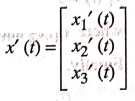
(i.e) x'(t) = Ax
where 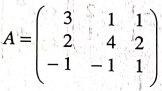 is the coefficient matrix of the given system.
Eigenvalues
of the matrix A are 2, 2, 4.
The
corresponding basis for the eigenvalues are obtained as
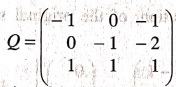
The
diagonalized matrix of Q is obtained as
D = Q‒1AQ = 
Substitute
A = QDQ‒1 into x' = Ax to obtain
x′(t) = (QDQ‒1)x or Q‒1x'
= DQ‒1x
Let
the function y: R → R3 defined by
y(t) = Q‒1x (t). It can be
differentiable and y'=Q‒1x'
The
original system can be written as
y'
= Dy. Let 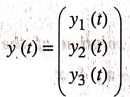
we
can rewrite y' = Dy as follows
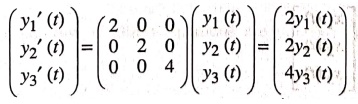
By
comparing on both sides, the three equations are as follows.
y'1 = 2y1, y'2=2y2
and y3'=4y3, are independent to each
other.
The
general solution of these equation is
y1(t)
= c1e2t, y2(t)
= c2e2t, y3(t)
= c3e4t
where
c1, c2 and c3 are arbitrary constants.
Finally,
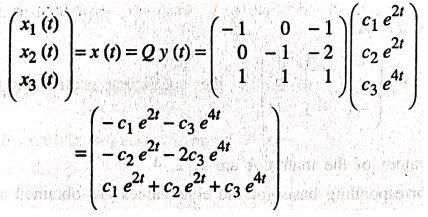
yields the general solution, of the original
system. This solution can be written as
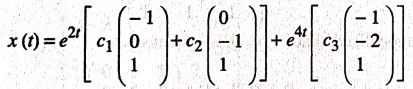
The
general solution is
x(t) = e2tz1 + e4tz2
where
z1 ∈ Eλ1, and z2 ∈ E λ2
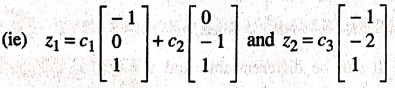
Example 19
Find the general
solution of the system of differential equations;
x1'=x1+x3;
x2=x2+x3
& x3' = 2x3.
Solution:
Let
The derivative of x denoted by x', is defined by
Let 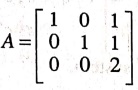 be the coefficient matrix of the given system.
Then
the system as the matrix equation can be written as x1 = Ax
……………….(1)
The
eigenvalues of the matrix A are 1, 1, 2.
The
corresponding basis for the eigenvalues are obtained as
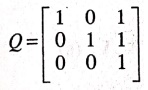
Then
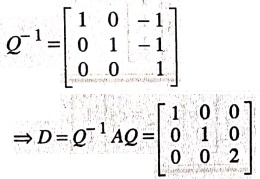
Substitute
A=QDQ‒1 in to x'=Ax to obtain x'(t) = (QDQ‒1)x (or) Q‒1x'
= DQ‒1x
Let
the function y: R→ R3 defined by
y(t) = Q‒1x (t) ⇒ y′(t) = Q‒1x'.
The
original system can be written as y' = Dy.
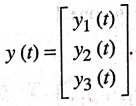
Then
y' = Dy can be written as
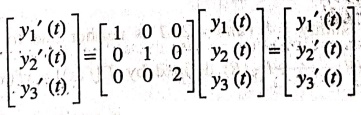
This
gives y'1=y1(t), y'2=y2(t),
y3' = 2y3(t).
The
general solution of these equations are y1(t)
= c1et, y2(t) = c2et
& y3 (1) = c3 e2t.
Finally
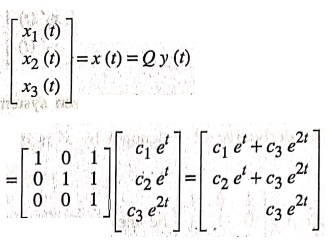
which
yields general solution of the original system.
This
solution can be written as
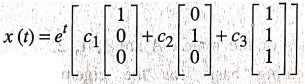
The general solution is x(t) = et[z1
+ z2 +z3]
where
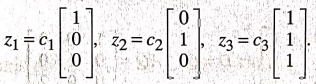
Linear Algebra: UNIT II: Linear Transformations and Diagonalization : Tag: maths, mathematics : - System of Differential Equations
Linear Algebra: UNIT II: Linear Transformations and Diagonalization
Under Subject

Linear Algebra
MA25C02 2nd Semester | 2025 Regulation
Related Subjects

English Essentials II
EN25C02 2nd Semester | 2025 Regulation | 2nd Semester 2025 Regulation

Tamils and Technology தமிழர்களும் தொழில்நுட்பமும்
UC25H02 2nd Semester | 2025 Regulation | 2nd Semester 2025 Regulation
Linear Algebra
MA25C02 2nd Semester | 2025 Regulation
Transforms and its Applications
MA25C03 2nd Semester EEE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Physics (CE) II
PH25C02 2nd Semester Civil, Agri Depts | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Physics (CSIE) II
PH25C03 2nd Semester AIDS, CSE, IT, CSE(CY) Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Applied Physics (EE) II
PH25C04 2nd Semester EEE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Physics (ME) II
PH25C05 2nd Semester Mechanical Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Applied Chemistry (CE) II
CY25C02 2nd Semester Civil Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Applied Chemistry (ME) II
CY25C03 2nd Semester Mechanical Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Electron Devices
EC25C01 2nd Semester ECE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Digital Principles and Computer Organization
CS25C06 2nd Semester AIDS, CSE, IT, CSE(CY) Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Basic Electrical and Electronics Engineering
EE25C01 2nd Semester | 2025 Regulation | 2nd Semester 2025 Regulation

Basic Civil and Mechanical Engineering
GE25C01 2nd Semester EEE Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Data Structures using CPlusPlus
CS25C05 2nd Semester ECE Dept | 2025 Regulation | 2nd Semester 2025 Regulation
Engineering Drawing
ME25C01 EEE, Mech, Agri, EEE Depts | 2025 Regulation | 2nd Semester 2025 Regulation
Data Structures and Algorithms
CS25C04 2nd Semester EEE Dept | 2025 Regulation

Circuits and Network Analysis
EC25C02 2nd Semester ECE Dept | 2025 Regulation | 2nd Semester 2025 Regulation

Engineering Mechanics
ME25C02 2nd Semester Mech, Civil, Agri Depts | 2025 Regulation | 2nd Semester 2025 Regulation
Object Oriented Programming (OOPs)
CS25C07 2nd Semester CSE, CSE(CY) Depts | 2025 Regulation | 2nd Semester 2025 Regulation